Sahand Tangerami
Mechanics and Machatronics Engineer
Control Theory, Machine Learning, Multi-Agent Systems, and Complex Systems Researcher
MATLAB and C++ Tutor
- EmailSahandterami@gmail.com
- Google ScholarSahand Tangerami
- LinkedInSahand Tangerami
About Me
Researcher, Programmer, Tutor, and Dream Chaser
I hold an M.Sc. in Mechanical Engineering from K. N. Toosi University with several years of experience collaborating with international research teams in the United States.
I am a research-oriented control engineer working at the intersection of control theory, optimization, and learning-based methods for complex dynamical systems. My background spans from classical and modern control to data-driven and intelligent control approaches, with strong emphasis on bridging theoretical analysis and real-world implementation. I have worked on motion control and state estimation problems in autonomous and robotic systems, including aerial and ground platforms, using advanced control techniques. My research experience includes model predictive control, data-driven modeling, and real-time control under practical constraints. I have gained practical experience in cybersecurity within robotics and in optimizing the performance of reservoir computing models for modeling applications. Currently, my work focuses on developing a learning-based controller by integrating attention mechanisms into reservoir computing models, as well as combining reinforcement learning with model predictive control to enhance safety, adaptability, and performance in autonomous vehicles. All my projects have been implemented using MATLAB, C++, or Julia.
Research Interests
Control
I am deeply interested in both control theory and systems engineering, with a specialized focus on Model Predictive Control (MPC) and Optimal Control. I am particularly passionate about exploring Learning-based Control to develop intelligent, adaptive strategies for complex autonomous systems.
Machine Learning
My interest in Machine Learning focuses on Data-driven Modeling and controller design. I am particularly fascinated by the potential of Reservoir Computing and Reinforcement Learning (RL) to capture complex dynamics and develop intelligent control strategies for high-dimensional systems.
Optimiztion
I aim to optimize control algorithms and ML models to achieve peak performance without sacrificing real-time feasibility. My focus is on leveraging Constrained Optimization and evolutionary techniques, such as Genetic Algorithms, to fine-tune system parameters and ensure efficient, reliable decision-making in time-critical applications.
Complex Systems
I am interested in the modeling and control of nonlinear dynamical systems, with a specific focus on Multi-Agent Systems (MAS). I aim to use data-driven modeling to analyze how local interactions within networked systems lead to global emergent behaviors and to develop strategies that ensure the stability and performance of interconnected agents in complex, large-scale environments.
Autonomous and Connected Vehicles
My research interest involves the development of Autonomous and Connected Vehicles (ACVs), focusing on the synergy between perception and control. I aim to enhance vehicle performance by integrating advanced sensing technologies with intelligent, optimal, and robust control strategies, ensuring safe and efficient navigation in dynamic, real-world environments while leveraging vehicle-to-everything (V2X) communications.
Robotics
I am interested in exploring Learning-based Control to enhance the adaptability and intelligence of robotic systems. My research focus extends to autonomous navigation and SLAM, as I am passionate about finding innovative ways to integrate data-driven control strategies with real-time mapping to solve complex locomotion challenges in unknown environments.
Activities and Hobbies
Writing
For me, writing is like breathing, it gives my mind freedom to wander, lets my imagination take flight, and transforms the whispers of my inner world into vivid stories on the page. Through writing, I find a place where my soul feels truly alive.
Watching Anime
Anime introduces me to a boundless fantasy world where imagination has no limits and anything can happen, allowing me to experience stories beyond the constraints of live‑action films, while also teaching valuable life lessons.
Running
Running not only keeps me fit but lets me appreciate my environment and the feeling of my body in motion. My enthusiasm for running even earned me third place in a national competition during my teenage years.
Football
Playing football has always been more enjoyable for me than watching it. From a young age, I loved the teamwork aspect, particularly as a goalkeeper, taking responsibility for the last line of defense, a position I became passionate about thanks to my role model, Gianluigi Buffon.
Resume
Education
2018-2022
M.Sc. in Mechanical Engineering with focus on Dynamics and Control
K. N. Toosi University of Technology - IranThesis: Design and Implementation of Model Predictive Control for Improving Stability of a Vehicle Teleoperation System
Supervisor: Dr. Ali Nahvi
2013-2018
B.Sc. in Mechanical Engineering
Yasouj University - IranThesis: Autonomous Trajectory Tracking of a Quadrotor via Kalman-based State Estimation
Supervisor: Dr. Behrooz Rahmani
Teaching and Research Experience
2026 - Present
Research Collaborator
Shiraz University - IranUnder the supervision of Prof. Mohammad Hasan Asemani
Research Area: Model predictive control, reinforcement learning, and autonomous vehicles
2024 - Present
Research Collaborator
University of New Mexico - United StatesUnder the supervision of Prof. Francesco Sorrentino
Research Area: Reservoir computing, deep learning, data-driven modelling, optimization, complex systems, and multi-agent systems
2020 -2022
Research Collaborator
University of Southern California - United StatesUnder the supervision of Dr. Hamid Chabok
Research Area: Photoacoustic imaging and light and sound interaction
2019 - 2023
Graduate Research Assistant
Virtual Reality Lab. - K.N. Toosi University of Technology - IranUnder the supervision of Dr. Ali Nahvi
Research Area: Control theory, model predictive control, autonomous vehicles, and driver modeling
Graduate Teaching Assistant
K.N. Toosi University of Technology- IranTeaching assistant of Automatic Control, Dr. Ali Nahvi
Teaching assistant of Technical English Language, Dr. Ali Nahvi
Publications
2026
Extreme Vulnerability to Intruder Attacks Destabilizes Network Dynamics
Authors: Amirhossein Nazerian, Sahand Tangerami, Malbor Asllani, David Phillips, Hernan Makse, Francesco SorrentinoJournal: Nature Communications
[DOI:10.1038/s41467-026-76342-5]
Optimizing the Network Topology of a Linear Reservoir Computer
Authors: Sahand Tangerami, Nicholas Mecholsky, Francesco SorrentinoJournal: Systems and Control Letters
2021
Three-Dimensional Dynamic Lensing by Enhanced Light-Sound Interactions
Authors: Hamid Chabok, Amirhossein Feiz, Sahand Tangerami, Pooya Sharyari, Soroush ShafighProvisional U.S. Patent
For access to the patent text, please contact Dr. Hamid Chabok (chabok@usc.edu)
Skills
Control Skills:
Model Predictive Control (MPC)
Automatic Control
LQR and LQG
Observer Design (Kalman Filter)
Fuzzy Logic Control
Lyapunov Stability and Master Stability Function Analysis
Learning based Control
Machine Learning Skills:
Reservoir Computing
Attention Mechanisms
Data-Driven Modelling
Artificial Neural Networks (ANN)
Reinforcement Learning
Optimization Skills:
Linear and Quadratic Programming
Simulated Annealing
Constrained Nonlinear Optimization
Multi-Parametric Programming
Genetic Algorithms
Coding Skills and Optimization Frameworks:
MATLAB
C++ (for controller implementation)
Julia (for optimization)
Matlab Optimization Toolbox
MOSEK
YALMIP
Ipopt and JuMP Libraries (Julia)
Other Software Skills:
SOLIDWORKS
CarSim
Git
ABAQUS
Unreal Engine
ANSYS FLUENT
Laboratory Skills:
Microcontroller Programming
Real-Time Motor Control Implementation
Electrical Motor Wiring and Testing
Sensor Integration and Calibration
Hardware-in-the-Loop Testing
Robotic System Assembly and Debugging
Human-in-the-Loop Testing
Sensor Fusion for State Estimation (IMU)
Projects
Some of my Works
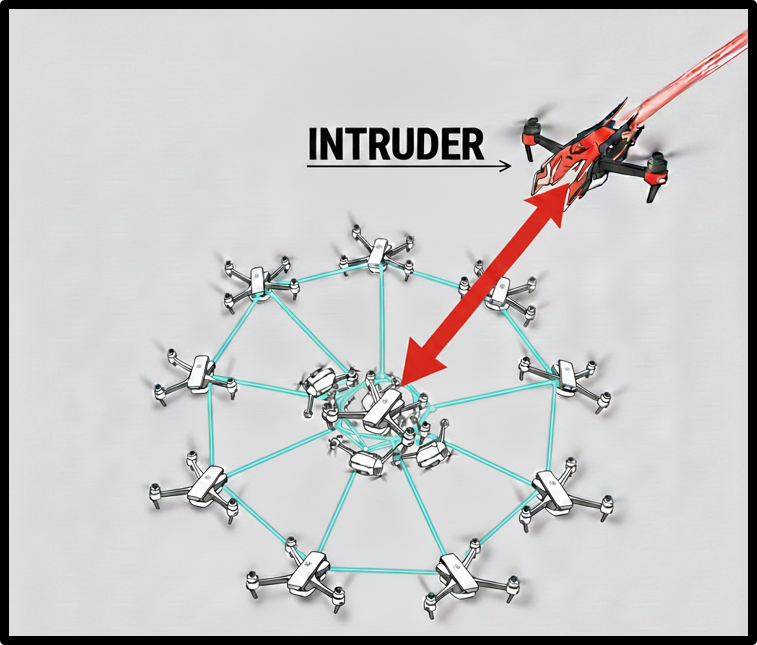
Vulnerability Analysis in Networked Dynamical Systems
Completed Research Project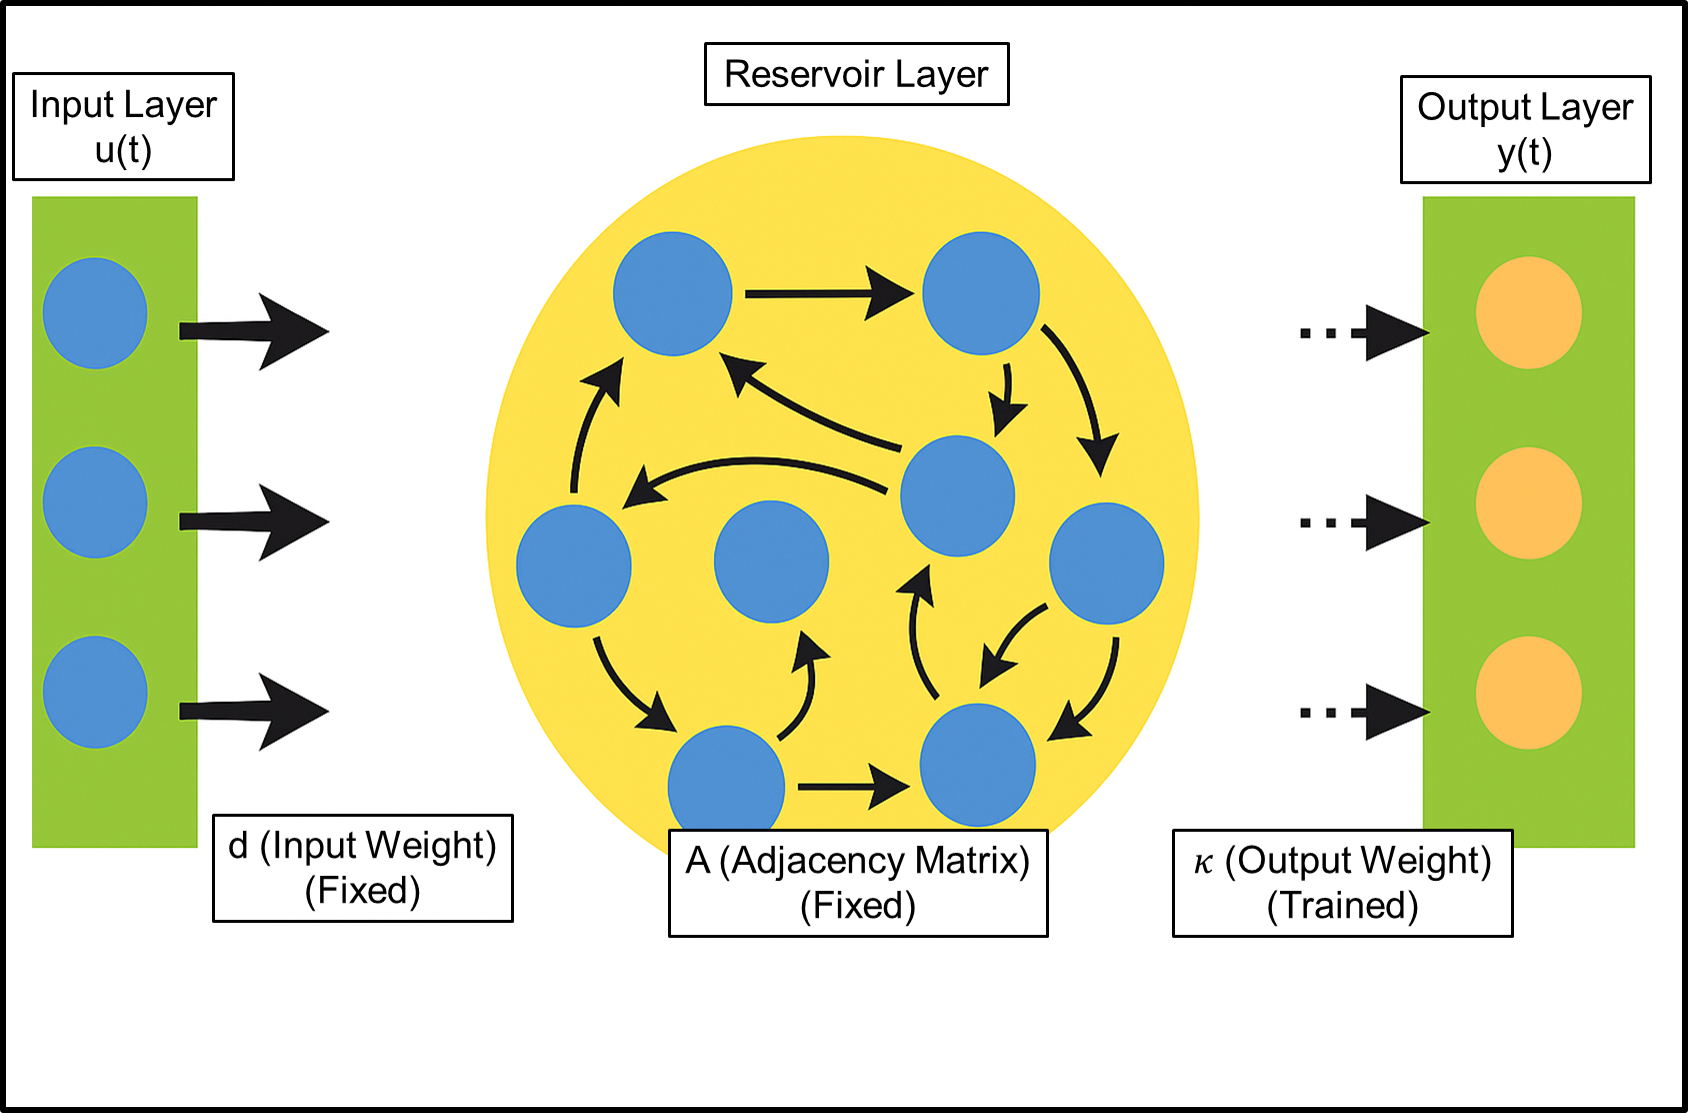
Topology Optimization of a Linear Reservoir Computer for Estimation Tasks
Completed Research Project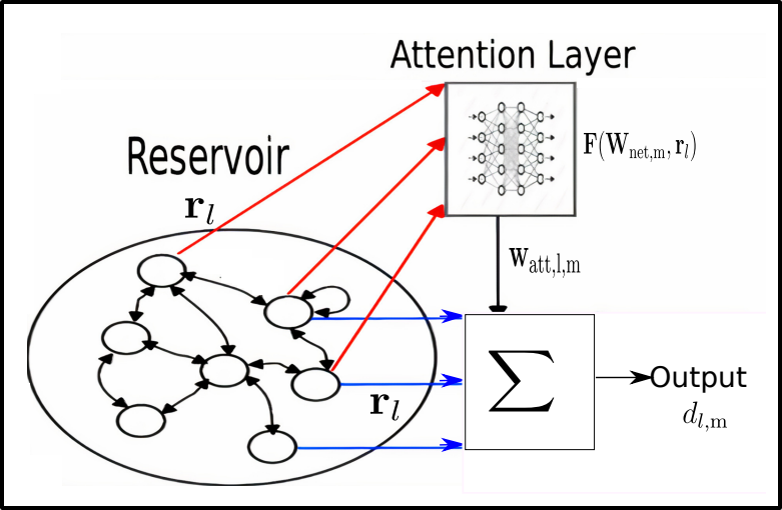
Reservoir-Based State Estimation of Partially Observable Multi-Agent Systems
Completed Research Project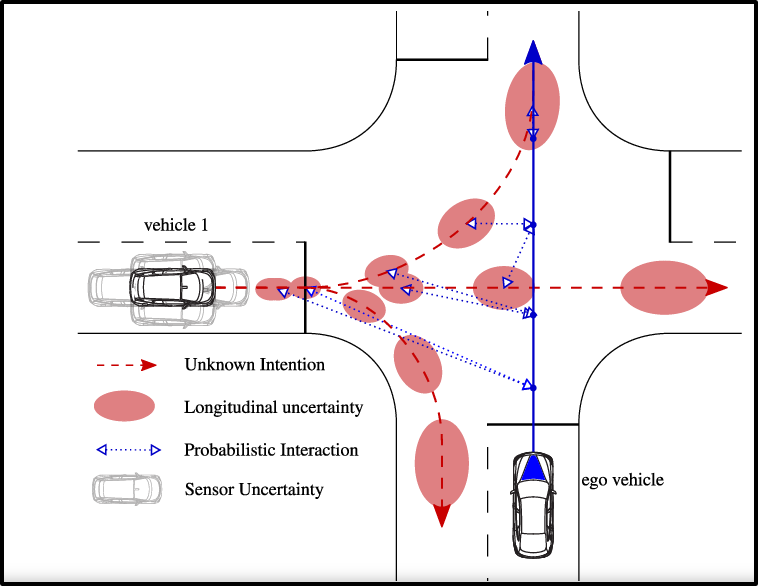
Safe Learning-Based Control of Autonmous Vehicles
Ongoing Research Project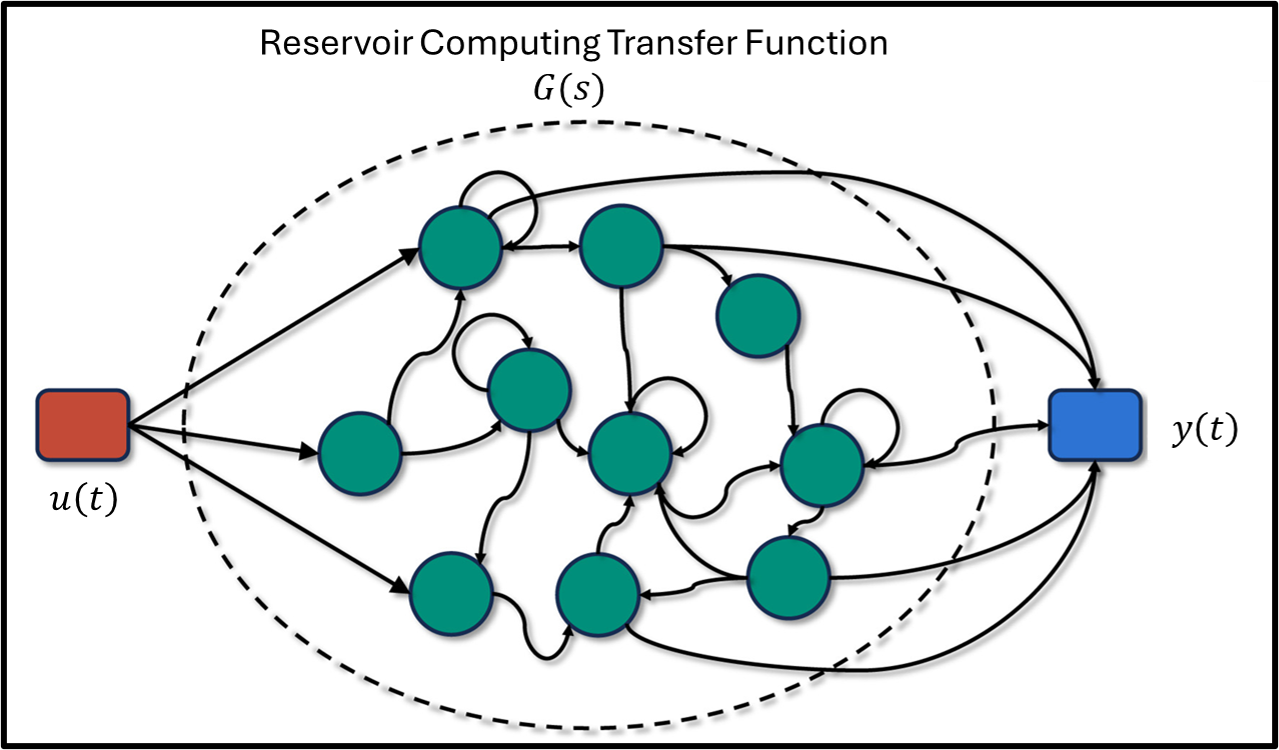
Reservoir Computing as a Nonlinear Transfer Function Framework
Ongoing Research Project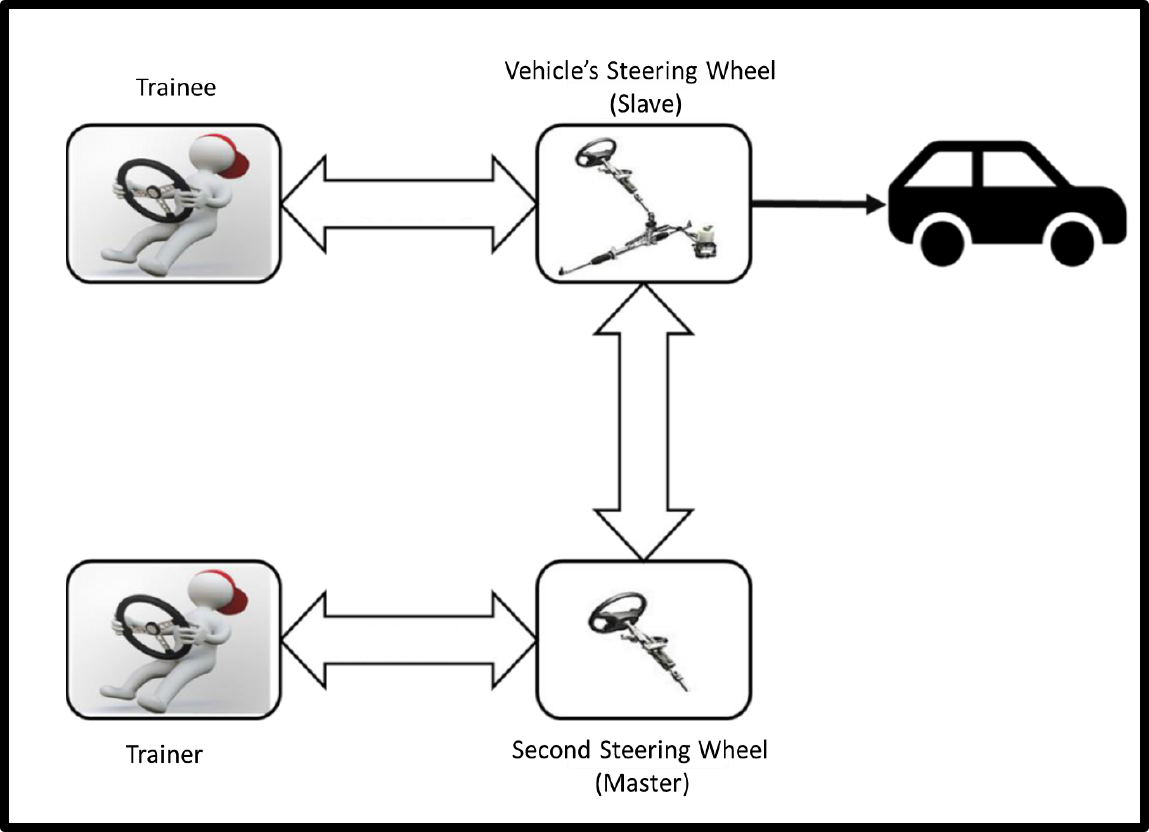
M.Sc. Thesis: Design and Implementation of Model Predictive Control for Improving Stability of a Vehicle Teleoperation System
Completed Research Project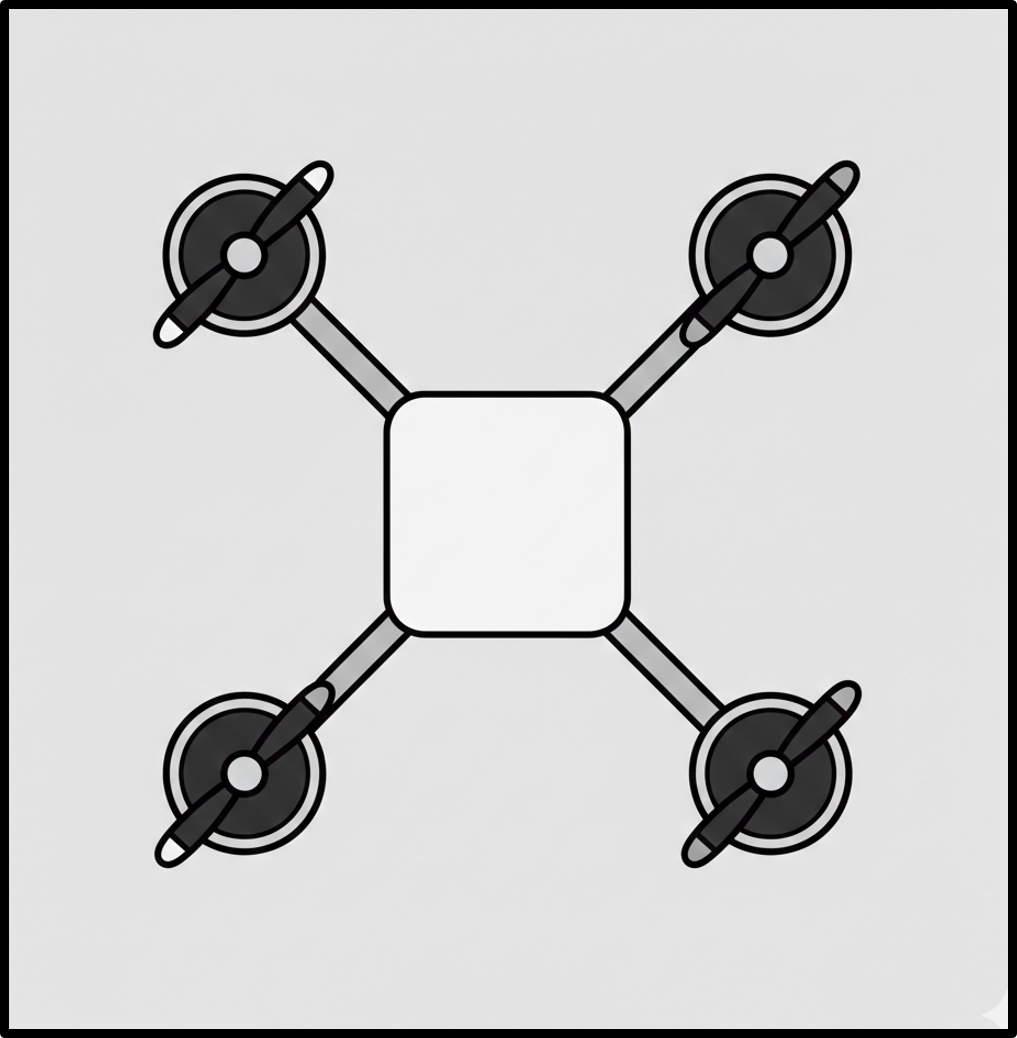
B.Sc. Final Project: Controller Design for Trajectory Tracking of an Indoor Quadrotor
Completed Research Project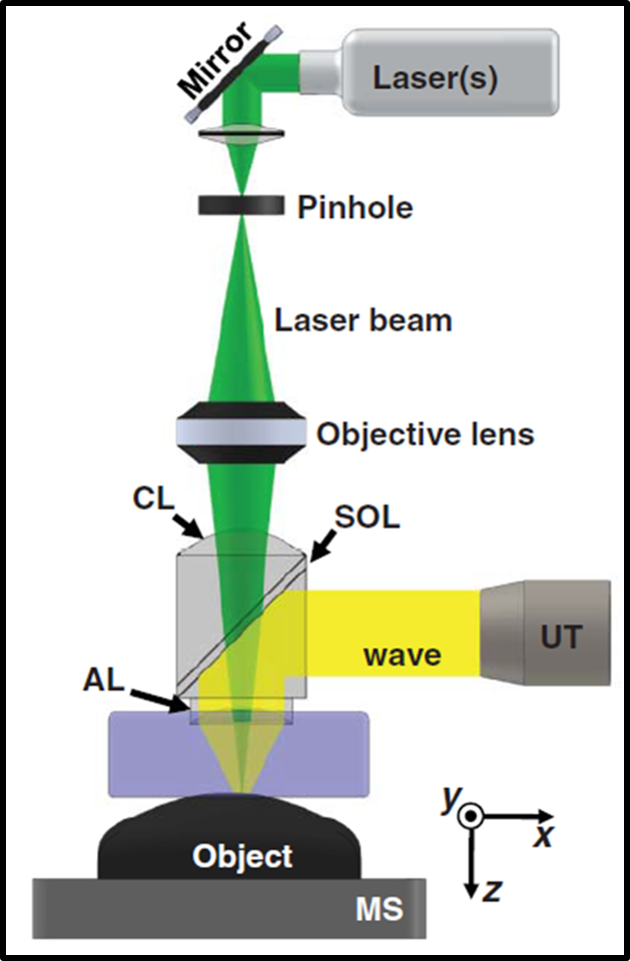
Photoacoustic Microscopy of the Brain Through the Intact Skull
Completed Research Project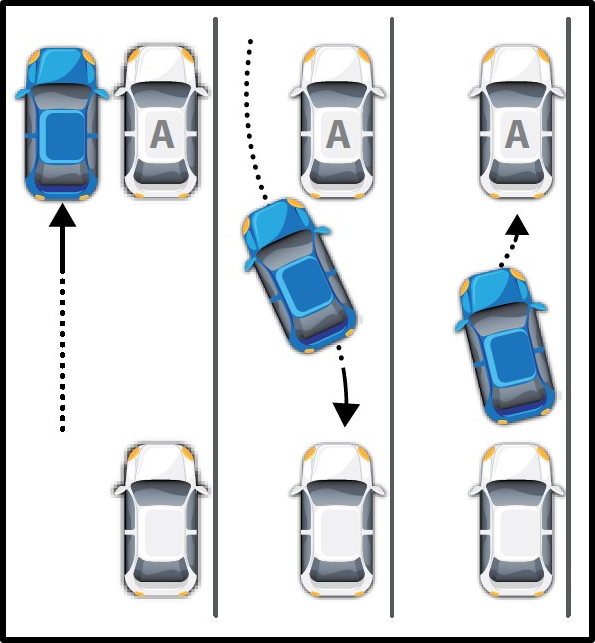
Optimal Parallel Parking of an Autonomous Vehicle Using LQR and Fuzzy Logic Control
Completed Course Project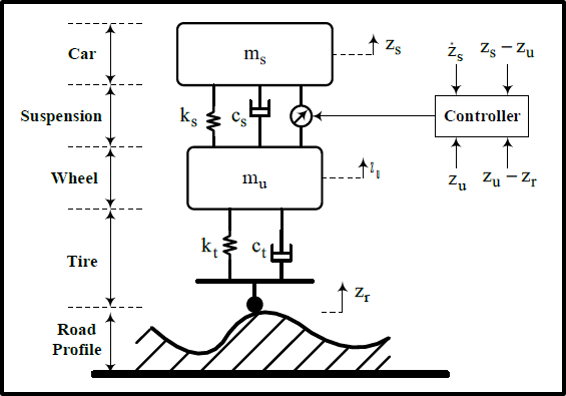
Controlling the Vehicle’s Active Suspension System Using LQR and LQG
Completed Course Project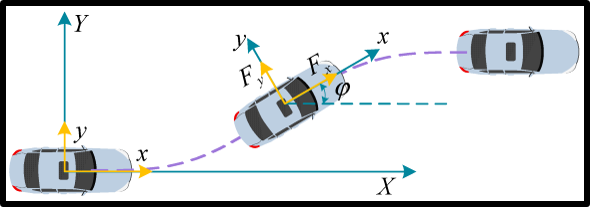
Controlling the Lateral Motion of a Vehicle Using State Vector Feedback Control
Completed Course Project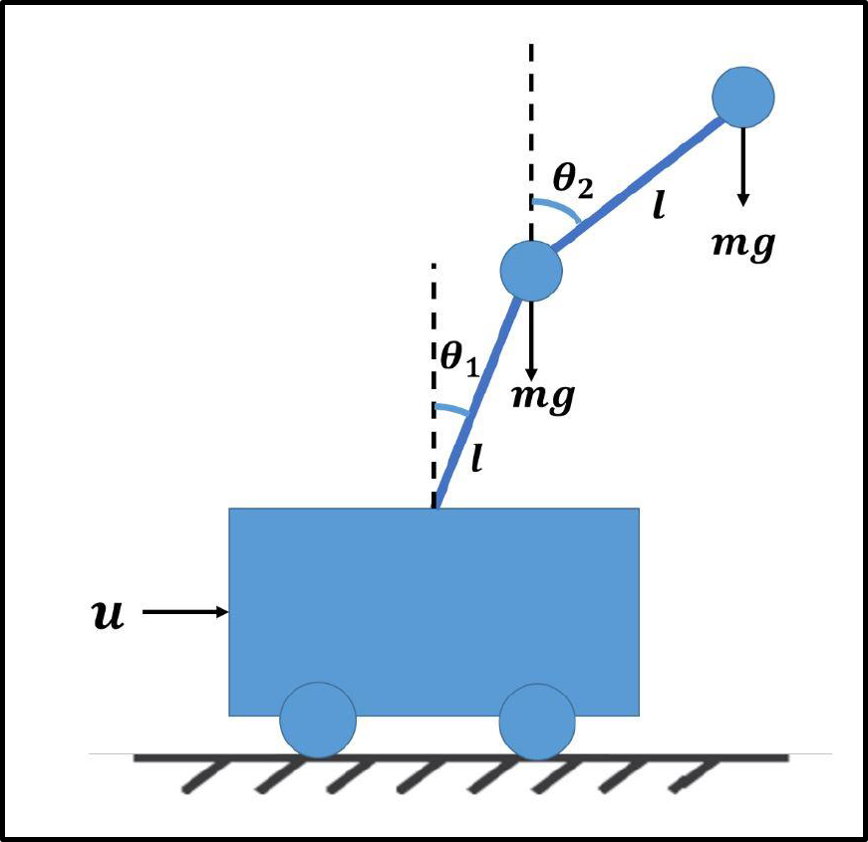
Controlling an Inverted Pendulum’s Angle Using LQR and Fuzzy Logic Control
Completed Course Project